
Polibot is a compact tracked mobile robot featuring a skid-steering locomotion system with passive suspension to improve terrain adaptability. Its mechanical structure measures 747×755×480 mm and weighs 90 kg, with a maximum payload capacity of 90 kg. It can reach a maximum speed of 1 m/s and provides up to 45 Nm of torque via its dual 24V DC motors. The robot is powered by a 24VDC 30Ah lithium battery pack, offering up to 4 hours of operation under normal conditions. It uses a dual-channel motor controller to drive two 24V DC motors, each equipped with encoders for closed-loop control.
Polibot integrates a range of onboard sensors, including:
The robot features multiple I/O interfaces, including 6x Digital/PWM/Analog inputs and RS232 communication. It is compatible with ROS (Robot Operating System) and supports control and development through C/C++ libraries and custom ROS nodes.
References:
Reina, G., and Mantriota, G. (February 24, 2025). “On the Climbing Ability of Passively Suspended Tracked Robots.” ASME. J. Mechanisms Robotics. July 2025; 17(7): 075001. https://doi.org/10.1115/1.4067624
Ugenti, Galati, Mantriota, Reina, Analysis of an all-terrain tracked robot with innovative suspension system,
Mechanism and Machine Theory, 182, 2023, 105237, https://doi.org/10.1016/j.mechmachtheory.2023.105237

Polibot is a compact tracked mobile robot featuring a skid-steering locomotion system with passive suspension to improve terrain adaptability. Its mechanical structure measures 747×755×480 mm and weighs 90 kg, with a maximum payload capacity of 90 kg. It can reach a maximum speed of 1 m/s and provides up to 45 Nm of torque via its dual 24V DC motors. The robot is powered by a 24VDC 30Ah lithium battery pack, offering up to 4 hours of operation under normal conditions. It uses a dual-channel motor controller to drive two 24V DC motors, each equipped with encoders for closed-loop control.
Polibot integrates a range of onboard sensors, including:
The robot features multiple I/O interfaces, including 6x Digital/PWM/Analog inputs and RS232 communication. It is compatible with ROS (Robot Operating System) and supports control and development through C/C++ libraries and custom ROS nodes.
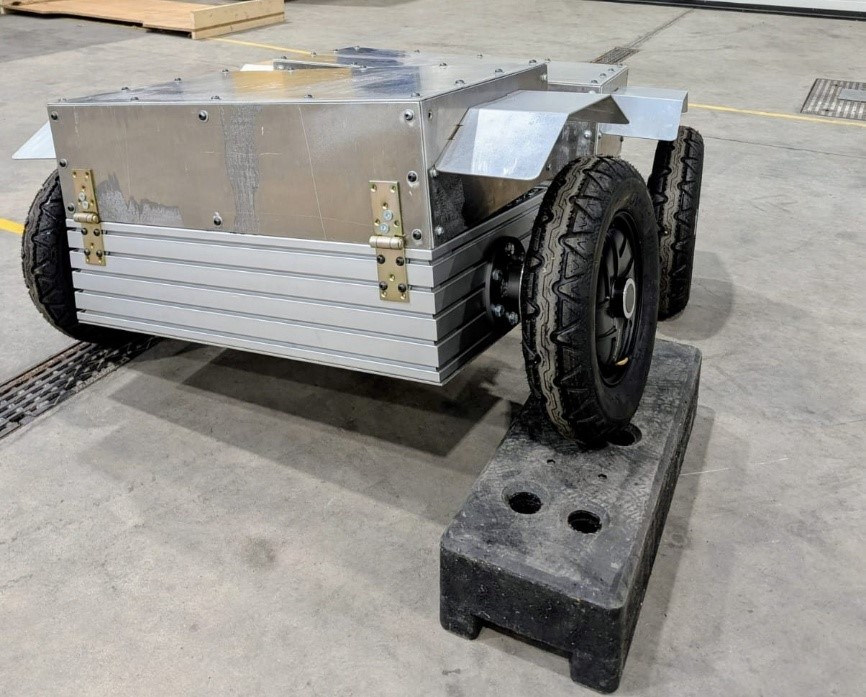
ARTI is a compact, center-articulated mobile robot specifically designed for precision agriculture and challenging environmental operations. The robot is characterized by an articulated chassis that significantly improves maneuverability and ground adaptability. The robot is moved by four electric in-wheel motors and powered by a 48 VDC 30Ah LiFePO4 (Lithium Iron Phosphate) battery pack.
Mechanical Characteristics:
Electric in-wheel Motor Features:
Sensors and Control Systems:
ARTI is ideally suited for research and operational deployment in precision agriculture, where maneuverability, stability, and adaptability to uneven terrain are essential.